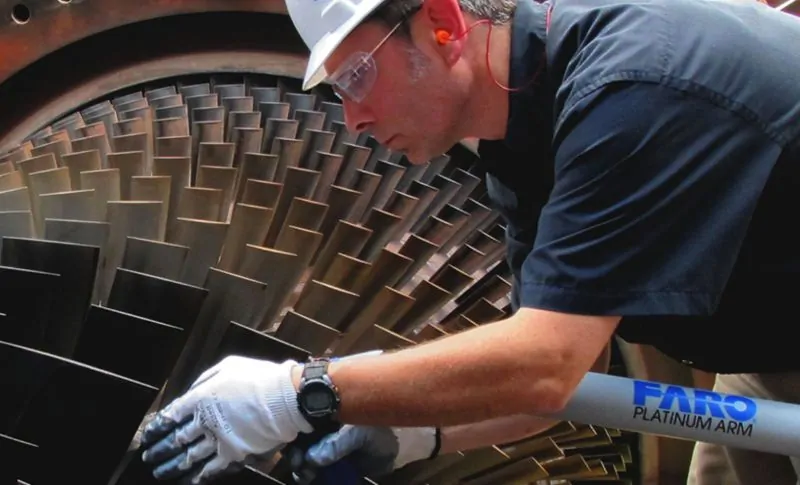
Digital laser scanning captures surface geometry by measuring distances between a sensor and points on an object. The scanner emits laser light, records returns, and converts those measurements into a point cloud. Software then organizes points into a three-dimensional model. This process supports inspection, reverse engineering, CAD comparison, and documentation when physical dimensions must be recorded accurately. The result depends on capture strategy, surface condition, registration, and quality control.
How the Scanner Measures a Surface
For manufacturers, scan data provides a measurable record of parts, tools, assemblies, and large structures. A project using digital laser scanning services captures dense coordinate data without touching the surface, which preserves freeform contours that contact probes cannot reach easily. The resulting file can guide dimensional analysis, CAD reconstruction, or inspection planning when engineers need evidence.
A laser scanner sends a beam toward a surface and measures the returned signal. The instrument records the angle and distance for each sampled location, then converts those values into three-dimensional coordinates. Millions of coordinates can describe edges, holes, radii, slots, and irregular transitions with a consistent reference system.
Short-range scanning suits components that fit within a controlled measurement area. Long-range scanning captures buildings, structures, equipment, or other large subjects from multiple positions. The scanner records overlapping views, and technicians combine them through registration.
Surface Condition and Scan Planning
Surface condition directly affects returned laser data. Dark, reflective, transparent, or highly polished materials can scatter, absorb, or redirect the beam, leaving gaps or noisy points. Operators select scan angles and spacing that expose hidden areas without creating unnecessary overlap. A clean part also reduces false points caused by oil, dust, loose labels, or temporary fixtures.
Registration Preserves Geometry
Registration joins individual scans into one coordinate system. Software matches common features or target markers, then calculates each scan’s position and orientation. Technicians inspect residual errors after alignment because a small shift can create a false deviation across a broad surface. A reliable registration process separates capture error from actual part variation and preserves traceability for later review.
From Point Cloud to Surface Model
A point cloud is a collection of measured coordinates, not automatically a finished CAD model. Filtering removes isolated noise, while decimation reduces file size when excessive point density slows processing. Meshing connects neighboring points into triangular faces that describe the scanned surface. Engineers then inspect holes, edges, and thin features before using the mesh for comparison or reconstruction.
Engineers identify design intent, measure functional interfaces, and build surfaces or solids that match the captured geometry. Datum selection controls how the scan relates to a drawing or existing CAD file. For inspection, the software compares the measured cloud or mesh with nominal geometry and displays deviations through a color map and numerical readings.
Controlling Accuracy
Accuracy depends on the scanner, setup, surface, environment, and inspection method. A project specification should state the required tolerance, feature size, coordinate system, and deliverable format before capture starts. Those requirements determine scan resolution, control points, viewing positions, and processing settings. Without that planning, even a dense dataset can fail to answer the engineering question because it lacks the reference structure needed for comparison.
Calibration and verification checks confirm whether equipment performs within its stated capability. Reference artifacts with known dimensions provide a practical check before or after a scan. The team should document scanner identification, setup conditions, registration choices, filtering steps, and file revisions. Clear records allow another engineer to trace how a reported dimension moved from physical measurement to final result.
Practical Outputs
Inspection work needs aligned data, deviation results, and measurement records. Reverse engineering needs a clean mesh, section views, and CAD geometry built around functional requirements. Construction or facility documentation needs registered scans, views, and coordinates that relate to the site. The deliverable should preserve native data when future questions could require a new measurement.
Quality review should examine coverage before a model reaches production use. Missing areas, unstable targets, edge noise, and incorrect scale can change the result without obvious visual warning. A second review of registration and critical dimensions catches errors early.
Conclusion
Precise 3D surface geometry comes from a controlled chain of measurements, alignment decisions, processing steps, and verification checks. The point cloud records what the scanner measured, while the final model or inspection report gives that data an engineering purpose. Before commissioning a project, define the required tolerance, reference system, surface condition, and deliverable. That preparation helps the scanning team capture the right evidence and gives downstream users a defensible basis for design or quality decisions.
About the Author